
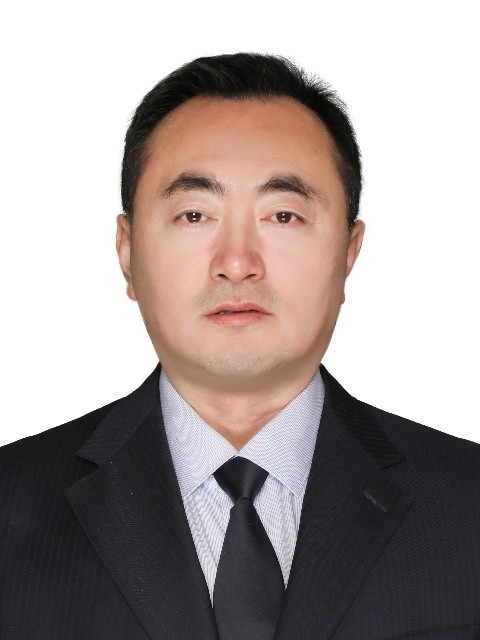
 岳明

|
个人信息Personal Information
教授
博士生导师
硕士生导师
性别:男
毕业院校:哈尔滨工业大学
学位:博士
所在单位:机械工程学院
学科:车辆工程. 控制理论与控制工程. 机械电子工程
办公地点:大连理工大学机械工程学院知方楼8017
电子邮箱:
移动版主页
研究领域
- .Yue, Ming.岳明,Wang, Hao.LaCAM*-SFDWA: Multi-autonomous mobile robots' path planning in warehouse environments based on spatio-temporal fuzzy dynamic window approach[J],TRANSACTIONS OF THE INSTITUTE OF MEASUREMENT AND CONTROL,2026
- Liu, Yujie.Yue, Ming.岳明,Zhao, Xudong.T-S fuzzy-based robust stability control for semi-trailer trucks by integrating tractor yaw moment and trailer active steering[J],APPLIED SOFT COMPUTING,2026,203
- Zhang, Lei.Yue, Ming.岳明.An optimal braking torque distribution control strategy for distributed drive electric vehicle under coasting regenerative conditions[J],PROCEEDINGS OF THE INSTITUTION OF MECHANICAL ENGINEERS PART D-JOURNAL OF AUTOMOBILE ENGINEERING,2026
- .Yue, Ming.岳明,Li, Xiang.Collaborative motion planning for multi Forklift-AGVs based on IDWA-APF and predistribution priority scheduling[J],PROCEEDINGS OF THE INSTITUTION OF MECHANICAL ENGINEERS PART C-JOURNAL OF MECHANICAL ENGINEERING SCIENCE,2026
- Li, Xiang.Yue, Ming.岳明,Wang, Rui,Zhao, Xudong.Integrated path planning and adaptive cooperative control for multi-cargo transportation systems utilizing priority game inheritance and neural network MPC approach[J],MEASUREMENT SCIENCE AND TECHNOLOGY,2026,37(37)
- .Cai, Lei.蔡磊,岳明,Guan, Hsin.Vehicle trajectory prediction model based on historical information integration[J],MEASUREMENT SCIENCE AND TECHNOLOGY,2026,37(26)